Hello everyone,
I am trying to setup the perimeter function and I encounter some problems.
I have no oscilloscope and my PC has no audio input, so I can not monitor the signals.
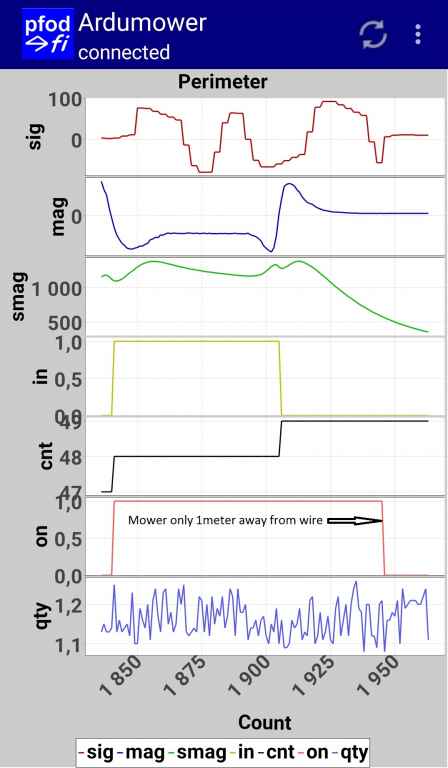
In the atached file is a screenshot of the perimeter plot (ADC calibration done, all motors and charger off) :
It seems to work, but the signal was apparently too weak and when I move the robot only one meter away from the wire, smag drops below 500 and the "ON" changes to 0.
I measured these values on the sender: 6.8V with 4ohms wire resistance -> 11.5w power. Perimeter led on on the sender board.
Thank you for giving me your opinion on this plot and helping me to solve this issue.
I am trying to setup the perimeter function and I encounter some problems.
I have no oscilloscope and my PC has no audio input, so I can not monitor the signals.
In the atached file is a screenshot of the perimeter plot (ADC calibration done, all motors and charger off) :
It seems to work, but the signal was apparently too weak and when I move the robot only one meter away from the wire, smag drops below 500 and the "ON" changes to 0.
I measured these values on the sender: 6.8V with 4ohms wire resistance -> 11.5w power. Perimeter led on on the sender board.
Thank you for giving me your opinion on this plot and helping me to solve this issue.
 erimeter(){