Azuritber Problem langsame Reaktion auf Bumper und Perimeter

Hi Bernard,
in the 1.43 MPU9250 branch you did some changes to get the esp running. Maybee you didn´t do that for the master?
I reloaded the 1.43 that i used til now and the esp works just nice. So i can eliminate some hardware problems.

Regards Michael
 
Hie Bernard i uploaded 1.5. Wifi is now functional. Thenk you very much.
Another Problem came up: The mower goes on error IMU Tilt after a couple of cm travel.
Can this be deactivated or adjusted?
Thanks
Michael
 
What is your config ?
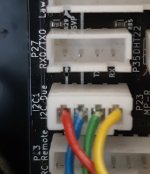
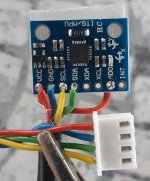
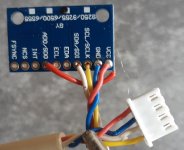
RTC error is possible if IMU kill the I2C line ,so if your never see RTC error before, try to check IMU connection,for GY-521 you can use standard I2C2 connector and JC2 to 3.3V .Do not forget AD0 shunt on IMU.
After calibration you need to have into setting IMU tilt and roll near 0 .
 
All of the above. Maybe the gy521 is faulty. I have a second one. Will try it. The rtc error occured after 20 minutes running time.
 
So i changed to i2cport5 and maybe this redolved teh rtc error. Not much test time on this but we will see.
Two other problems showed.
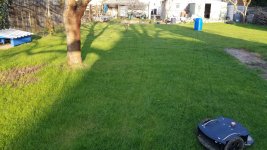
Tho mower didnt drive in a straight line and in the by lane mode the lanes are not praralel. I set the line direction to for example 90 and -90. This behavior started with the gy521. With the mpu9250 it drove nice and straight. Do i miss something in the setup? Or is ir maybe the gy521 ?
On the pics you can see what i mean.

The second one yesterday it shut off for no reason. I started in by lane mode and went into the house. After 20min i tried to connect with wifi but no success. I thought about a problem with wifi but it was completely powered down. No idea why.


Michael
 

Anhänge

  • 20210406_170829.jpg
    20210406_170829.jpg
    5,1 MB · Aufrufe: 15
  • 20210408_183936.jpg
    20210408_183936.jpg
    5,2 MB · Aufrufe: 15
What about Gyro/Yaw calibration and test IMU result ?
Please share console of Gyro/Calibration and the list var.

On first picture ,if lane is set to 90 and -90 ,it's very strange,Are you sure that mower is really in the lane 90/-90 and not in lane 2 or 3.
What the max lane length into setting /Bylane lane max length.

On picture 2 the long circle arc is the MPU6050 Drift and normaly limit by the setting/ IMU /delay between 2 calib.
 
Hi Bernard,
i set all lanes to Parrrallel for example 90/-90, 45/-135 etc.
Max length is 20m. The mpu9259 made nearly straight lanes with that settings
Picture 2 shows the left circled lane and on the right side the lane is nearly straight. Thats both with the same settings. ca. 2minutes between.

Regards Michael
 
Console after Startup:
SETUP
--> ++++++++++++++++++++++++++++++++++* Start Robot Setup at 2502 --> +++++++++++++++++++++++++++
Load ErrorCounters
ErrorCounters address Start=500
ErrorCounters address Stop=522
UserSettings are read from EEprom Address : 2000 To 2501
Load Robot Stats
Robot Stats address Start = 800
Robot Stats address Stop = 826
IMU: found calib data
Load Calibration
Calibration address Start = 600
Calibration address Stop = 650
-------- IMU CALIBRATION --------
ACCEL GYRO MPU6050 OFFSET ax: -534 ay: 51 az: 1491 gx: 3 gy: 34 gz: 120
COMPASS OFFSET X.Y.Z AND SCALE X.Y.Z --> comOfs=0.00,0.00,0.00
comScale=2.00,2.00,2.00
.
--------------------------------- GYRO ACCEL INITIALISATION ---------------
MPU6050 connection successful
52
Initializing DMP...
Enabling DMP... Packet size 42
Wait 3 secondes to stabilize the Drift
AccelGyro Yaw: -0.01--------------------------------- IMU READY ------------------------------
Change to Area : 1
New sigcode in use : 1,1,-1,-1,1,-1,1,-1,-1,1,-1,1,1,-1,-1,1,-1,-1,1,-1,-1,1,1,-1,
matchSignal size=24
subSample=4
capture size=192
------------------------------- GPS Initialisation --------------------------------------------
Send config sentence
End of Gps Config
START
Ardumower 1.50-Azuritber GY-88
Config: Ardumower
press...
d for menu
v to change console output (sensor counters, values, perimeter etc.)
off

Watchdog is disable
ESP8266 in used : Use Arduremote over WIFI
 
Startup is OK but i want to see the list of variable : Option d and x if i remember well..
Also show me the calibration console with the wait ..
At end of calibration , pitch and roll need to be near 0.

Reduce delay between 2 calib to minimum and check that mower always stop for only 4 secondes and never change from ByLane to random mode (if it's append ,it's because drift is very important and only IMU replacement or location on mower (maybe avoid high vibration,i use velcro tape to fix it ) can solve issue

Certainly GY-521 is the problem, but i use 3 of them in other mower and they work better than MPU-9250
 
settings

---------- wheel motors -----------
motorAccel : 1500
motorSpeedMaxRpm : 21
motorSpeedMaxPwm : 150
motorPowerMax : 23.00
motorSenseRightScale : 1.87
motorSenseLeftScale : 1.65
motorPowerIgnoreTime : 2000
motorZeroSettleTime : 2000
motorRollDegMax : 100
motorRollDegMin : 20
DistPeriOutRev : 40
DistPeriOutStop : 15
motorForwTimeMax : 80000
DistPeriObstacleAvoid : 100
circleTimeForObstacle : 4000
motorRightOffsetFwd : -8
motorRightOffsetRev : 2
SpeedOdoMin : 50
SpeedOdoMax : 140
motorTickPerSecond : 200
motorLeftPID.Kp : 1.00
motorLeftPID.Ki : 0.40
motorLeftPID.Kd : 0.00
motorRightSwapDir : 0
motorLeftSwapDir : 0
motorRightOffsetFwd : -8
motorRightOffsetRev : 2
---------- mower motor -----------------
motorMowForceOff : 0
motorMowAccel : 1000.00
motorMowSpeedMaxPwm : 250
(motorMowSpeedMinPwm : 222
motorMowPowerMax : 60.00
motorMowSenseScale : 1.54
---------- bumper -----------------
bumperUse : 1
---------- drop -----------------
dropUse : 0
dropContact : 0
---------- rain ----------------
rainUse : 0
---------- DHT22 Temperature ---
DHT22Use : 0
MaxTemperature : 55.00
---------- sonar ---------------
sonarUse : 0
sonarLikeBumper : 0
sonarLeftUse : 1
sonarRightUse : 1
sonarCenterUse : 0
sonarTriggerBelow : 87
sonarToFrontDist : 30
---------- perimeter ------
perimeterUse : 1
perimeterTriggerMinSmag : 140
MaxSpeedperiPwm : 140
perimeterTrackRollTime : 1500
perimeterTrackRevTime : 2200
perimeterPID.Kp : 16.50
perimeterPID.Ki : 8.00
perimeterPID.Kd : 0.00
trackingPerimeterTransitionTimeOut: 1500
trackingErrorTimeOut : 10000
perimeterMagMaxValue : 2000
swapCoilPolarityRight : 0
swapCoilPolarityLeft : 0
read2Coil : 0
trackingBlockInnerWheelWhilePerimeterStrug : 1
DistPeriOutRev : 40
DistPeriObstacleRev : 30
DistPeriOutForw : 60
DistPeriObstacleForw : 25
---------- By Lanes mowing ----------
yawSet1 : 45.00
yawSet2 : 90.00
yawSet3 : 135.00
yawOppositeLane1RollRight : -135.00
yawOppositeLane2RollRight : -90.00
yawOppositeLane3RollRight : -45.00
yawOppositeLane1RollLeft : -135.00
yawOppositeLane2RollLeft : -90.00
yawOppositeLane3RollLeft : -45.00
DistBetweenLane : 30
maxLenghtByLane : 20
---------- lawn sensor---------
lawnSensorUse : 0
---------- IMU (compass/accel/gyro) ----
imuUse : 1
CompassUse : 0
stopMotorDuringCalib : 0
imuDirPID.Kp : 4.40
imuDirPID.Ki : 3.30
imuDirPID.Kd : 0.00
maxDriftPerSecond : 0.05
delayBetweenTwoDmpAutocalib : 360
maxDurationDmpAutocalib : 60
compassRollSpeedCoeff : 40
---------- model R/C ---------
remoteUse : 0
---------- battery --------
batMonitor : 1
batGoHomeIfBelow : 24.30
batSwitchOffIfBelow : 23.00
batSwitchOffIfIdle : 60
batFactor : 11.14
batChgFactor : 11.00
batFull : 29.40
batChargingCurrentMax: 1.50
batFullCurrent : 0.10
startChargingIfBelow : 28.60
chargingTimeout : 18000000
chgSenseZero : 511.00
batSenseFactor : 1.11
chgSense : 185.00
chgChange : 0
chgNull : 2
---------- charging station ----------------------------------
stationRevDist : 150
stationRollAngle : 120
stationForwDist : 30
stationCheckDist : 2
UseBumperDock : 0
dockingSpeed : 60
autoResetActive : 1
---------- odometry ------------------------------------------
odometryTicksPerRevolution : 690
odometryTicksPerCm : 8.50
odometryWheelBaseCm : 39.10
---------- GPS -----------------------------------------------
gpsUse : 0
stuckIfGpsSpeedBelow : 0.20
gpsBaudrate : 9600
---------- RFID -----------
rfidUse : 0
---------- RASPBERRY PI------
RaspberryPIUse : 0
---------- other ------------
buttonUse : 1
mowPatternDurationMax : 120
---------- user-defined switch -------
userSwitch1 : 0
userSwitch2 : 0
userSwitch3 : 0
---------- timer -----------
timerUse : 0
---------- bluetooth-----------------------------------------
bluetoothuse : 0
---------- esp8266 ------------------------------------------
esp8266Use : 1
esp8266ConfigString : 1234567321
---------- robot stats ---------------------------------------
statsMowTimeMinutesTrip : 14
statsMowTimeMinutesTotal : 78
statsBatteryChargingCounterTotal : 1
statsBatteryChargingCapacityTrip in mAh : 49.04
statsBatteryChargingCapacityTotal in Ah : 0.05
statsBatteryChargingCapacityAverage in mAh : 49.04
 
So it stopped mowing again with no error, just sitting on the lawn in "Wait" state.
In the motor Setting for what is the max RPM used? Looks like it has no effect to the speed of the mower.
In console is written to use arduremote for calibration. If i do this it calibrates and pitch and roll are near 0. but nothing showen on console.
So i am not sure how to give you this information.
 
Still having rtc errors. What i did:
USED I2CP5, changed to another gy521, that error comes not immediatly after booting. It takes some minutes. If it stays in ststion there is no problem for days. Do can this bee a bad conection or maybe noise ftom the motors?
 
RTC and IMU are in the same I2C line ,so it's difficult to know witch chip is in error and freeze the bus.

Into my 2 robomow i use GY-87 but connected to I2C1 port of the DUE
So RTC is connected on I2C and IMU on I2C1.

Something i can test:
For mpu-9250 i always test with IMU connected on the same I2C port that RTC (I2C).
It's rain this week end ,so i can open my denna mower and try to adapt the firmware to use I2C for RTC and I2C1 for IMU.
By this way if you have error RTC you are sure that it's RTC and same for IMU.

But my denna with RTC and GY-521 on I2C2 port (so same I2C line) always mow 3 hours a days without any error .
 
It was easier than i imagine.
2 NEW BRANCH ON GIT /
IMU-on-I2C1 for GY-521 connected to I2C1 port on PCB1.3
MPU9250-on-I2C1 for MPU-9250 connected to I2C1 port on PCB1.3

Now need to test for at least 20 hours of mowing without any stop.
GY521 I2C1 1.jpgGY521 I2C1.jpgMPU9250 I2C1.jpg
 
Oben